
The 2027 7th International Conference on Robotics and Control Engineering (RobCE 2027) will be held in Shenzhen, China, from May 20 to 23, 2027, organized by Southern University of Science and Technology and Southeast University, supported by The Hong Kong Polytechnic University – Nanjing Technology and Innovation Research Institute and the Hong Kong Society of Mechanical Engineers (HKSME).
With the theme of "AI‑Driven Intelligent Control and Next‑Generation Robotic Systems", RobCE 2027 will serve as a premier international forum for presenting and exchanging technological advances and research results in robotics and control engineering. It aims to bring together leading researchers, engineers, and scientists from around the world to share the latest research findings and engineering practices, with a special focus on intelligent robotics, embodied intelligence, and AI‑driven autonomous systems.
The RobCE 2027 organizing committee invites proposals for special sessions. The special sessions will complement the regular program with new or emerging topics of particular interest at specific or cross‑disciplinary levels, including state‑of‑the‑art research in both academia and industry in special, novel, challenging, and emerging areas.
Special session proposals should be submitted by the prospective organizer(s) who will commit to promoting and handling the review process of the special session as Chair or Co‑Chair of the event. One special session lasts 2 hours, which allows 6‑10 oral presenters. If the number of presenters exceeds the capacity, some of them will be arranged to poster sessions. Presenters can submit abstracts for review.
The proposal template should clearly indicate: Title; Brief Description of the Session; Related Topics; Organizer's Information (Name, Affiliation, Biography, E‑mail, and formal photos of Session Chairs and Vice‑Chairs).
Please complete the special session proposal form and send it to info_robce@vip.163.com before the deadline.
DOWNLOAD CHINESE & ENGLISH TEMPLATE
Special Session 1: Trustworthy and Secure Embodied AI: Robust Perception, Intelligent Agents, and Cyber-Physical Safety for Autonomous Robotic Systems
|
Chair: 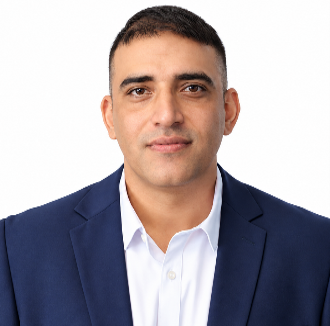
Dr. Kamran Aziz Lecturer Department of Digital Technologies, Hainan Bielefeld University of |
Vice Chair: 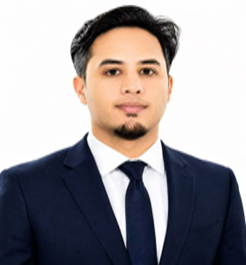
Dr. Umair Tariq Lecturer in Applied Computing (Digital Media Technology) Birmingham City University, UK (BIFCA, Wuhan Textile University, China) |
|
As robots and autonomous systems move from controlled laboratories into open, connected, real-world environments, the AI components that drive their perception, decision-making, and control face a growing range of threats: degraded or adversarially manipulated sensor inputs, spoofed or tampered communication messages, unreliable multimodal fusion, and large language model (LLM) and vision-language model (VLM) based agents that can be misled into unsafe or unauthorized actions. Robustness, security, and trustworthiness are therefore becoming core requirements of new-generation robotic systems rather than optional add-ons. |
|